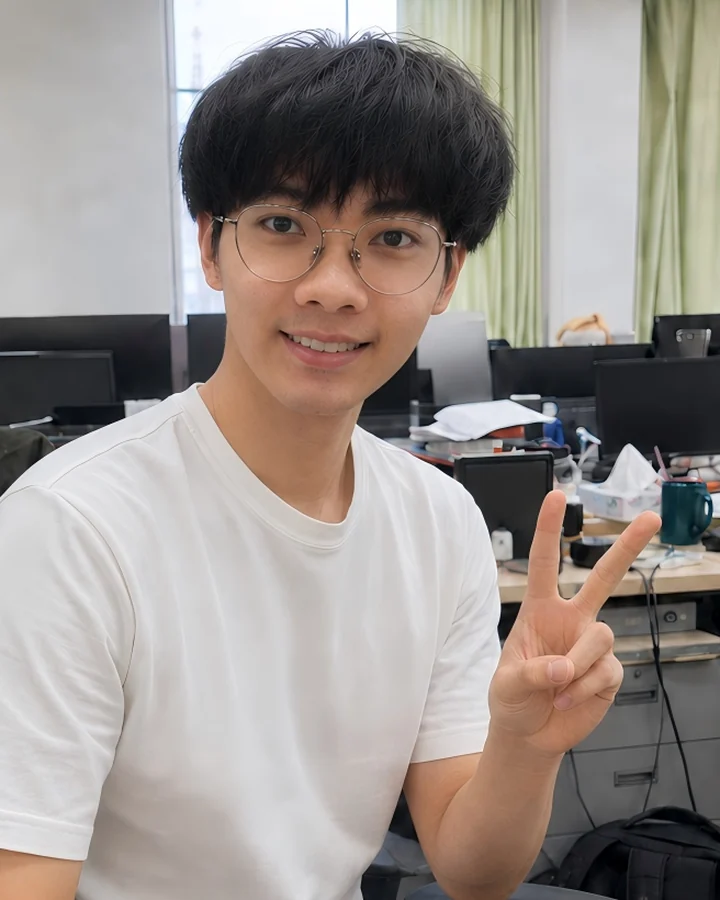
Zhiyou Guan in the office
Zhiyou Guan

Zhiyou Guan 关智友

向未曾抵达之境Toward the unknown

Co-founder & Chief Center Director · Freljord (Beijing) AI Laboratory

I’m a final-year Automation undergraduate at Northeastern University (new tab), currently in research collaboration and joint training at Beihang University (new tab). I work with my senior labmate, Prof. Jiarong Lin (new tab) (Associate Professor at Beihang, ranked among the world’s top 2% of scientists, and a National Young Talent), on UAV world models, spatial intelligence, and aerial agents.

In Fall 2027, I’ll begin a PhD in robotics with a full scholarship at the University of Hong Kong (new tab), joining Prof. Fu Zhang (new tab)’s MaRS Laboratory (new tab) and continuing the HKU–Beihang research collaboration and joint training. It’s a new challenge, and I look forward to spending more time on difficult research problems.

Beihang University (new tab)

Current research collaboration and joint training

Collaborating advisor: Prof. Jiarong Lin (new tab)

Program & advisor

GAMMA-LAB / γ-LAB. Associate Professor at Beihang · World’s Top 2% Scientists · National Young Talent · 2025 IEEE T-RO Best Paper Award winner

Working closely with my senior labmate, Prof. Jiarong Lin (Associate Professor at Beihang, ranked among the world’s top 2% of scientists, and a National Young Talent), on world models for aerial robots. Read more (new tab)

My research collaboration and joint training at Beihang are based at the Institute of Unmanned Systems, led by Prof. Xiwang Dong (new tab), its dean, a National Leading Talent and a Grade-II Professor.

Research

How can robots learn useful models of the physical world through interaction, and use that understanding to act?

My current work with my senior labmate, Prof. Jiarong Lin (Associate Professor at Beihang, ranked among the world’s top 2% of scientists, and a National Young Talent), focuses on world models for aerial robots. I’m also interested in spatial intelligence, reinforcement learning, agents, and recursive self-improvement, and how these ideas might contribute to artificial general intelligence (AGI).

Experience

SPARO (new tab)

Sep 2026 — Present

Multimodal Physical Agent Algorithms Intern

Leading the development of multimodal agents for the physical world, connecting environment understanding, task planning, and action execution.

  • Building agent toolchains and exploring VLM-based decision-making with semantic and geometric information.
  • Studying world-action models and vision-language navigation to plan actions from visual observations and language instructions.

Tencent (new tab)

2026.01 — 2026.07

AIGC / Large-model Algorithms Intern

Tencent Games · Game AI algorithms

Worked on multimodal agents for game NPCs, combining visual input, text, and scene state for task planning and execution.

  • Developed ReAct and tool-calling workflows, with short- and long-term memory and reflection.
  • Built evaluation workflows for character consistency, error analysis, and difficult-case collection.

Dongfeng Motor (new tab)

2025.01 — 2025.05

Autonomous Driving Systems Architecture Intern

Autonomous & Intelligent Systems R&D · L3 driving

Worked on a layered L3 driving architecture and multi-sensor fusion, connecting sensor interfaces, temporal alignment, and edge inference.

  • Implemented CAN/LIN parsing and heterogeneous sensor synchronization with alignment below 5 ms.
  • Combined SLAM point clouds with IMU data and deployed an optimized vision model on Orin-X.

A*STAR CFAR (new tab)

2024.07 — 2024.10

Robotic Perception Algorithms Intern

Centre for Frontier AI Research, Singapore

Studied visual world models based on latent dynamics, learning environmental representations and future states from RGB-D observations.

  • Built an encoder and GRU transition model for self-supervised learning from robot-view sequences.
  • Designed multi-step latent rollouts and temporal consistency objectives, evaluating occluded object states and dynamic regions.

Research Intern · Multimodal Perception

Optoelectronic sensing & artificial intelligence

Worked on a multimodal driver-fatigue perception system, combining visual, audio, and time-series signals in a working application.

  • Explored audio time-series encodings, human-motion features, and attention-based models.
  • Integrated perception modules into a real-time system and registered associated software copyrights.

Open-source projects

Project records →

Navigation & combat robotics (new tab)

Nav Combat Workspace

A unified ROS workspace connecting localization, navigation, vision, chassis and gimbal control, referee communication, and behavior-tree decisions.

  • ROS 1
  • C++
  • Navigation
  • Behavior trees

During my undergraduate studies: 15 national competition awards, including 9 national first prizes, and 38 software copyright registrations as first author.
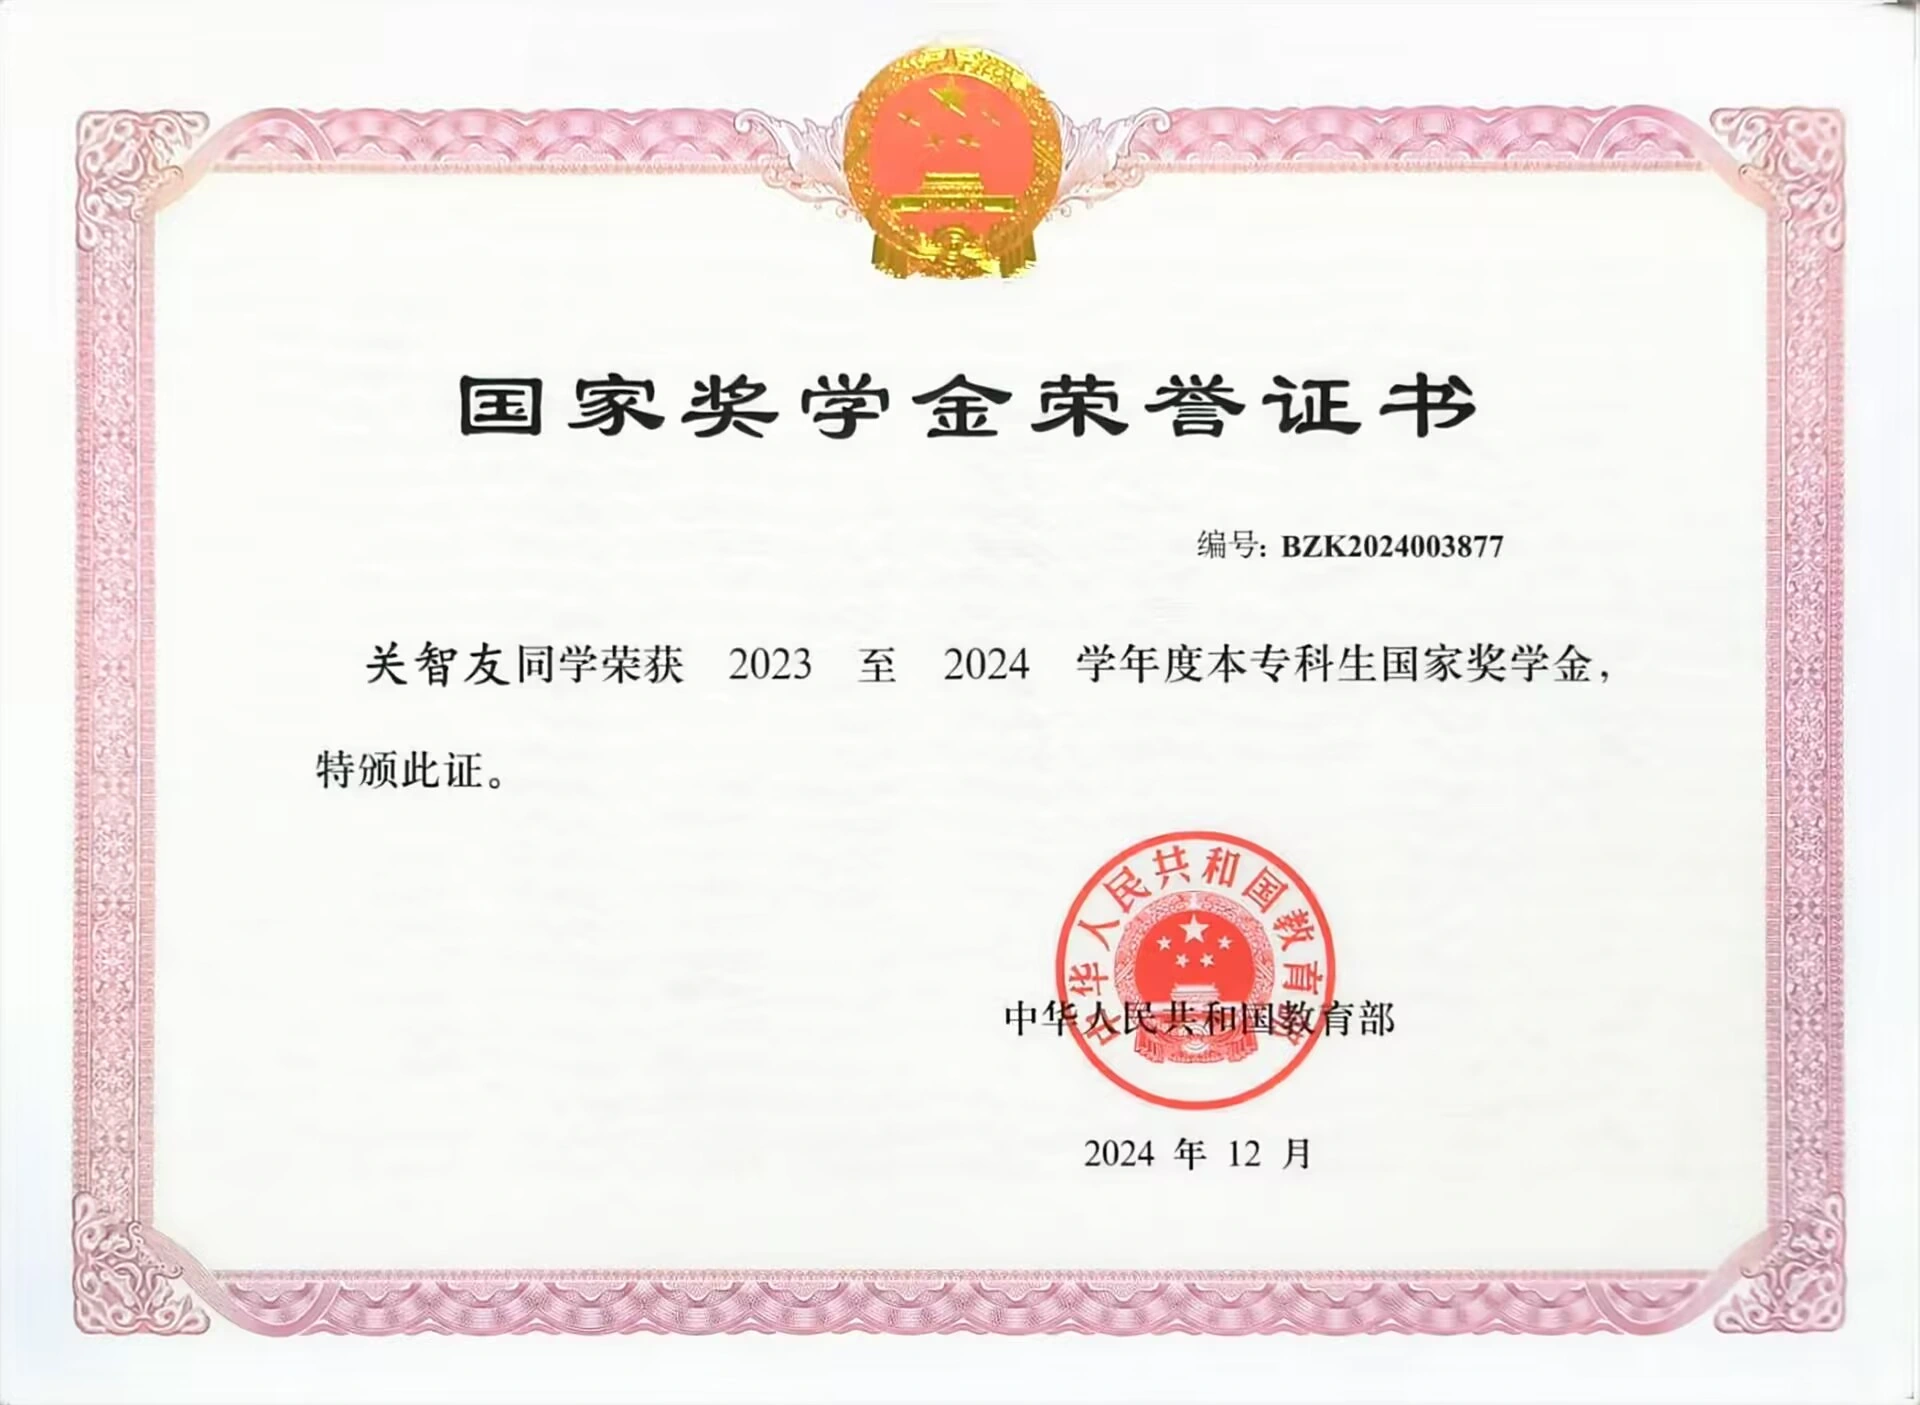
National Scholarship certificate
2024

National Scholarship

2023–2024 academic year · First in the school’s comprehensive ranking

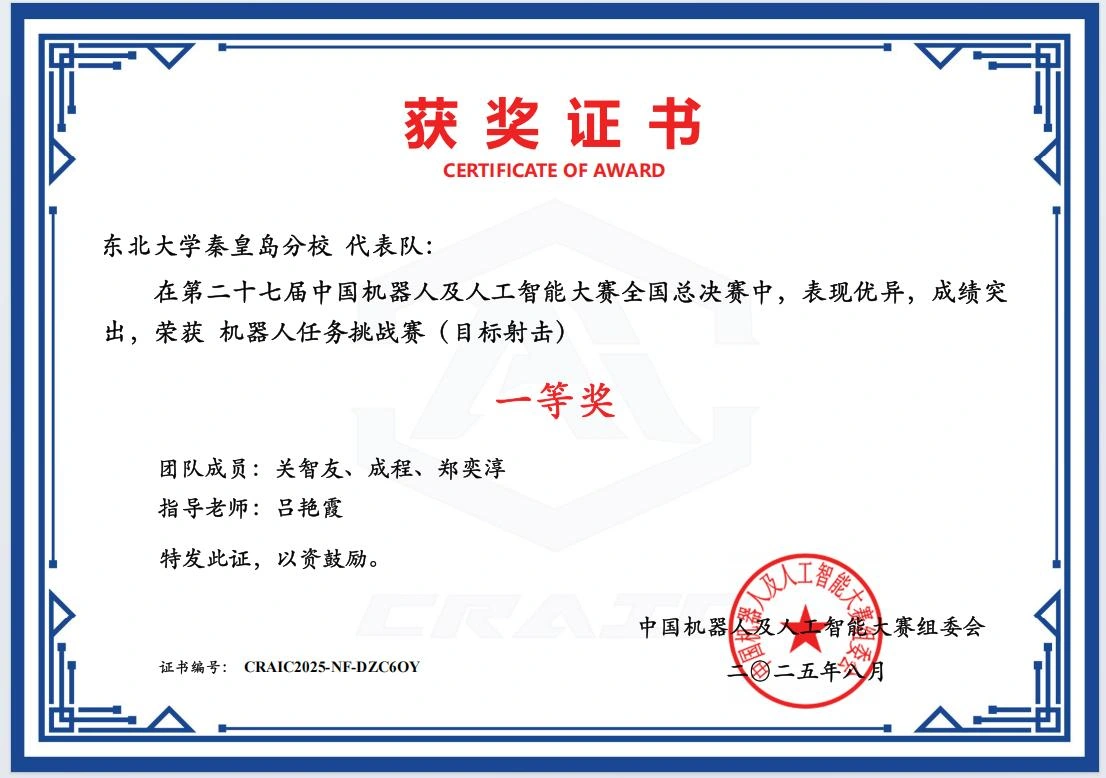
National Champion · CRAIC certificate
2025

National Champion · CRAIC

Robot Task Challenge · Team captain

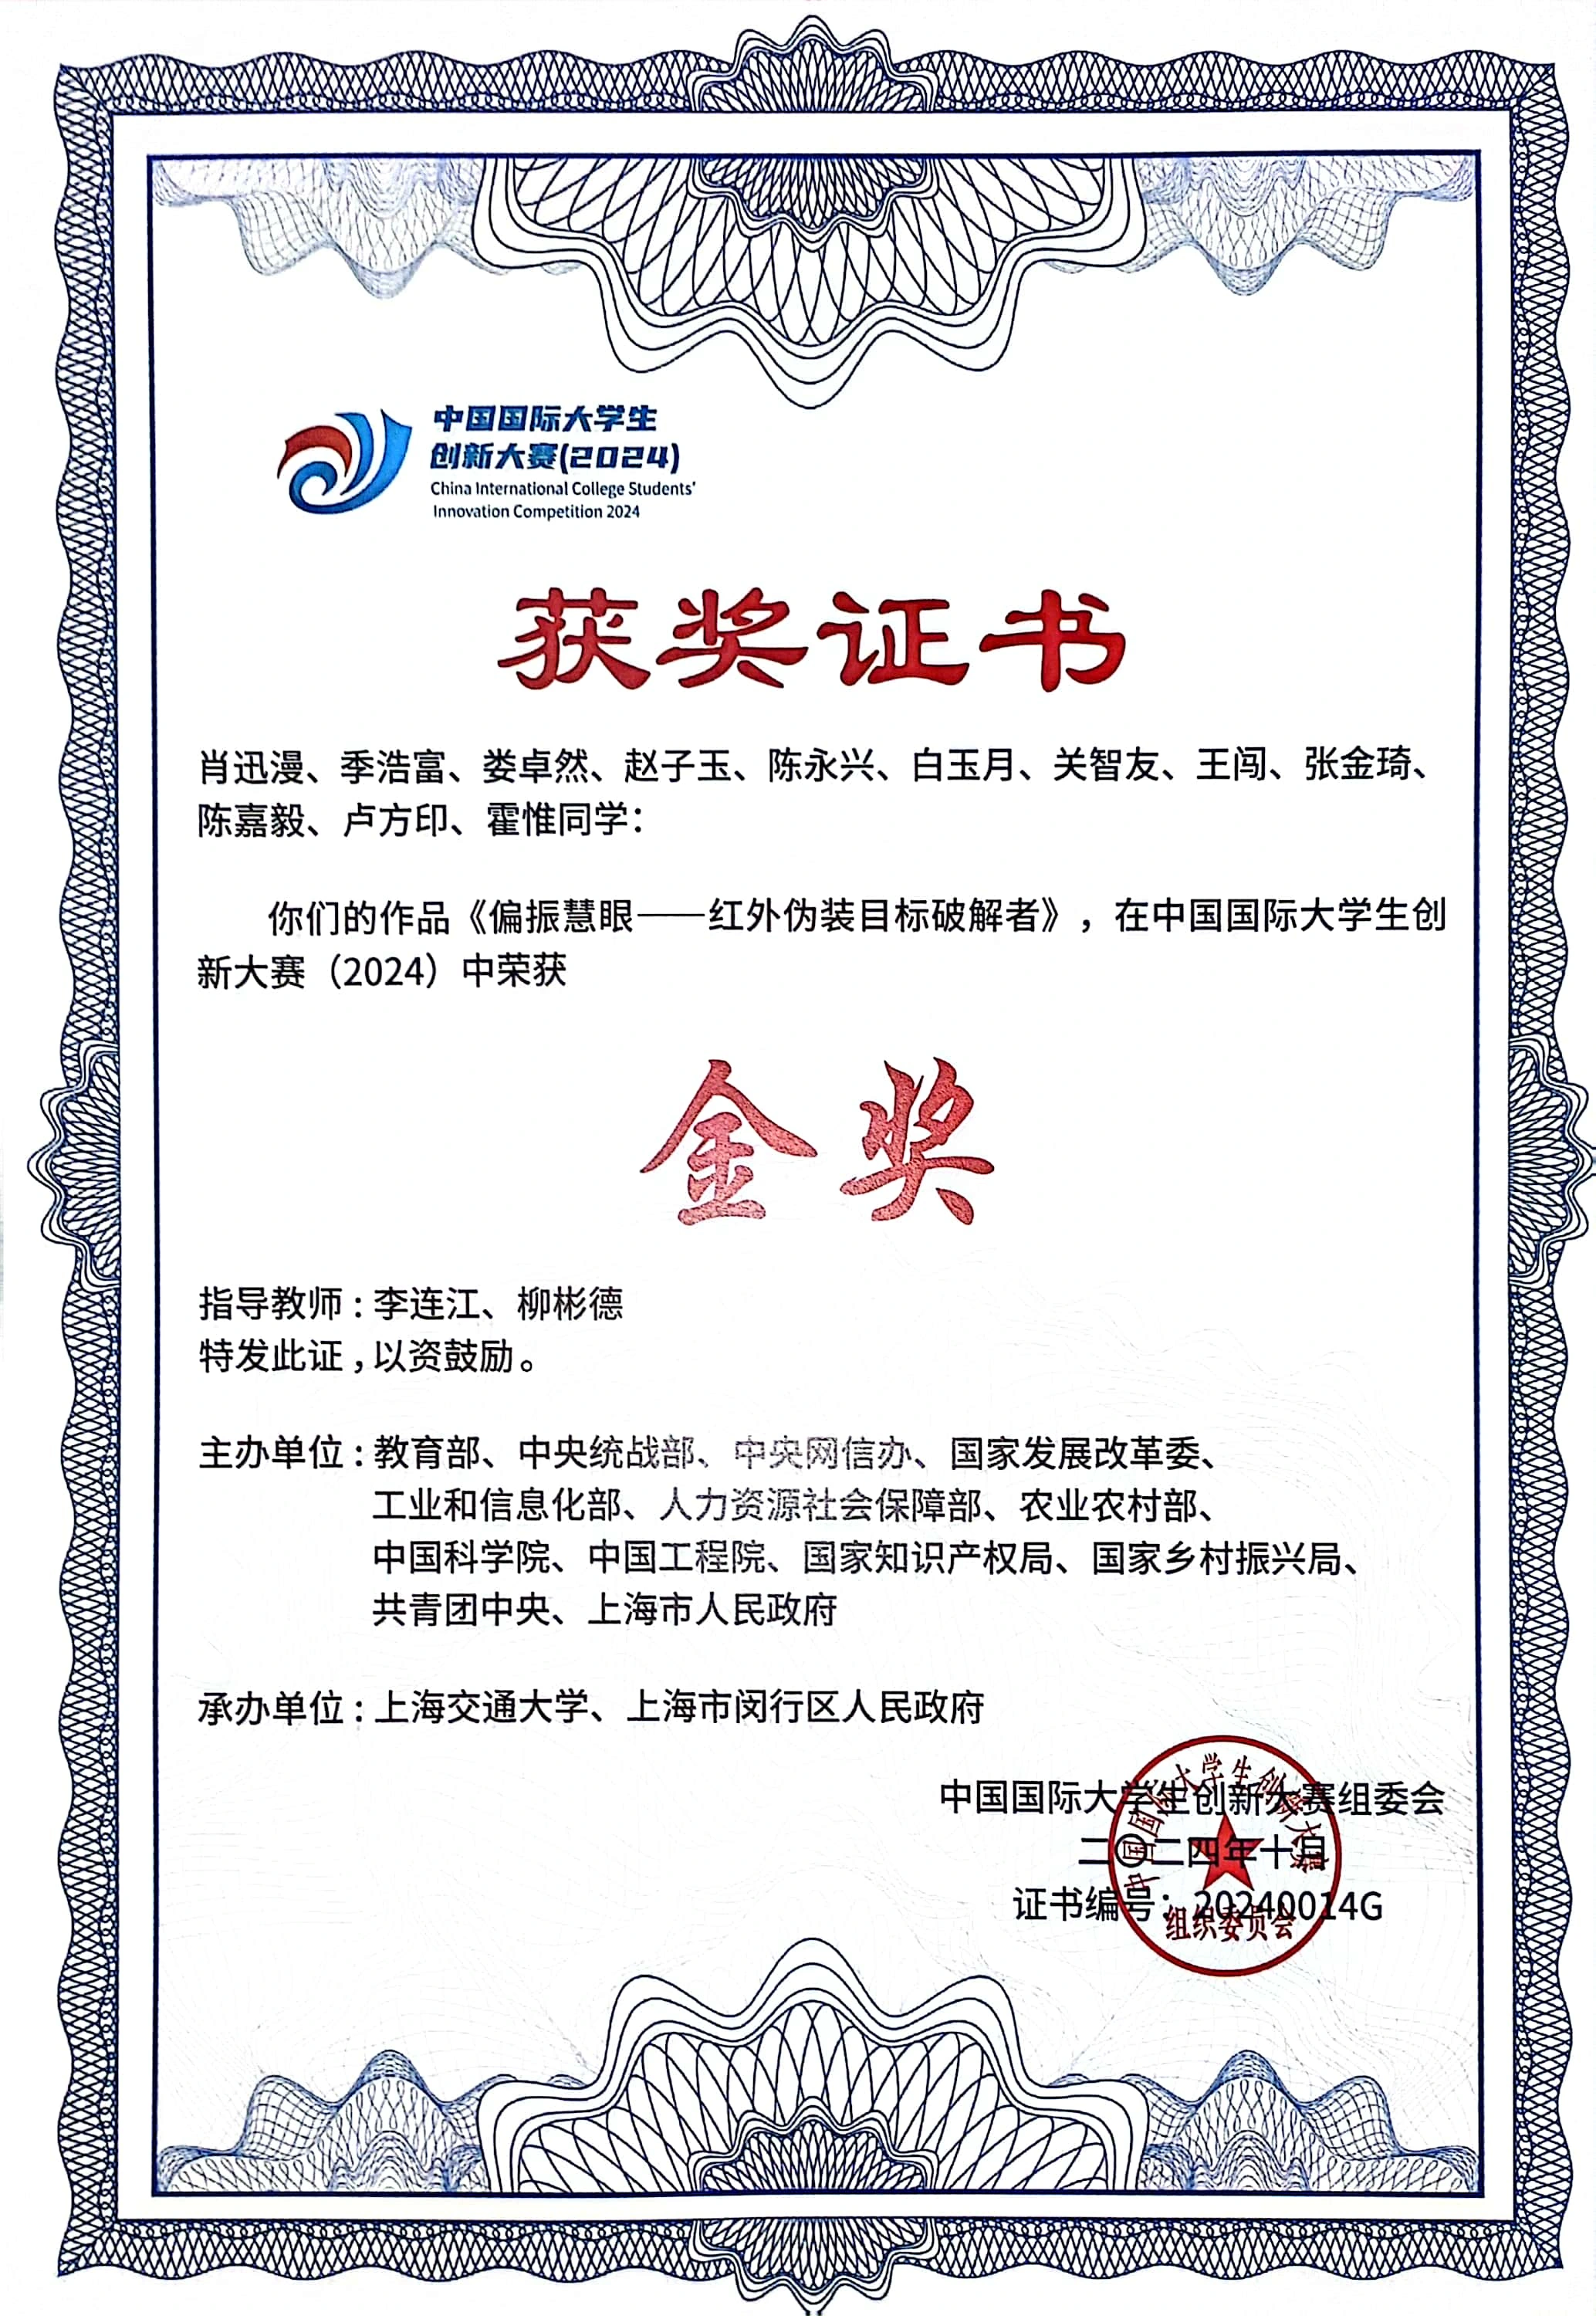
Gold · China International College Students’ Innovation Competition certificate
2024

Gold · China International College Students’ Innovation Competition

National final · Software lead

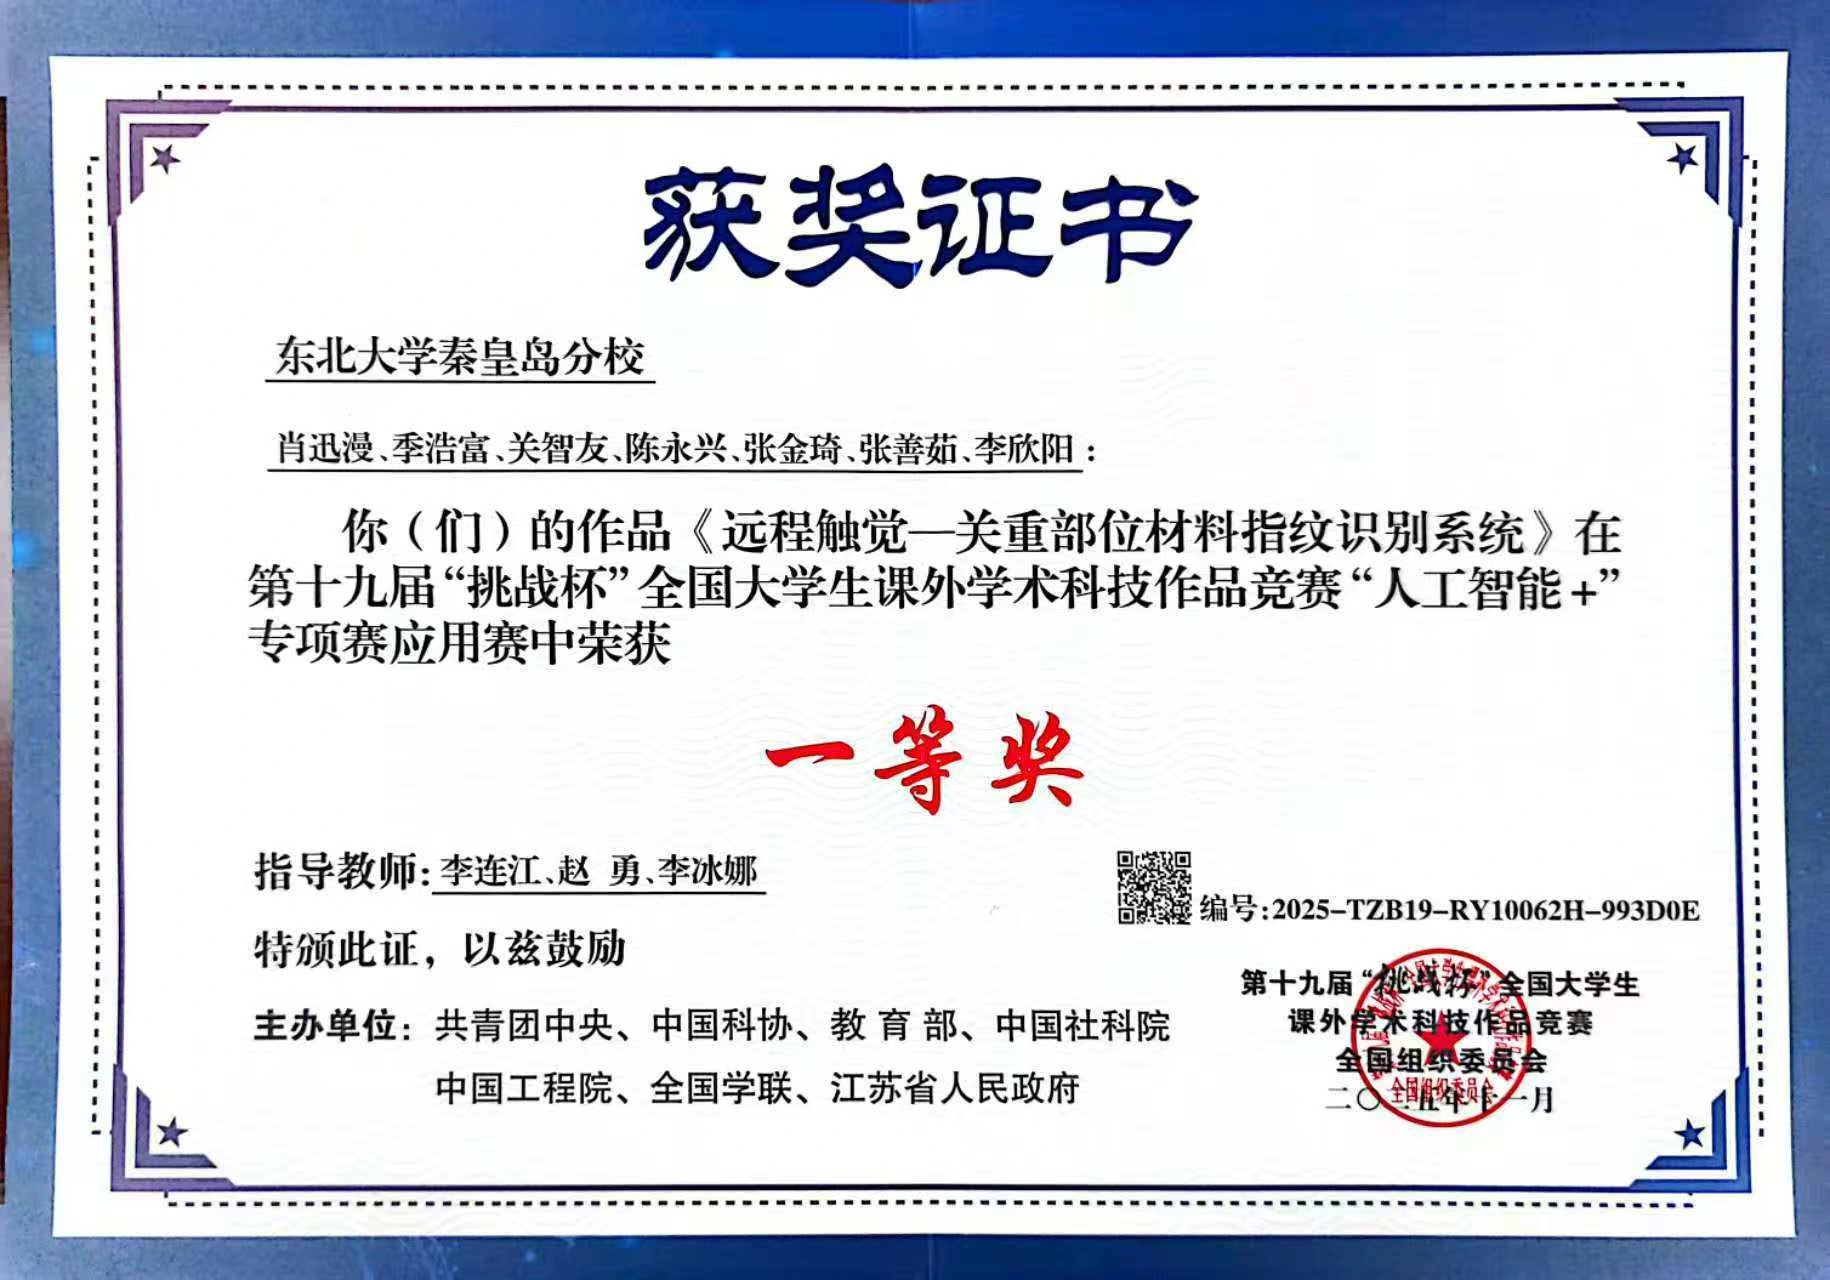
National First Prize · Challenge Cup certificate
2025

National First Prize · Challenge Cup

AI+ special track · Algorithm lead

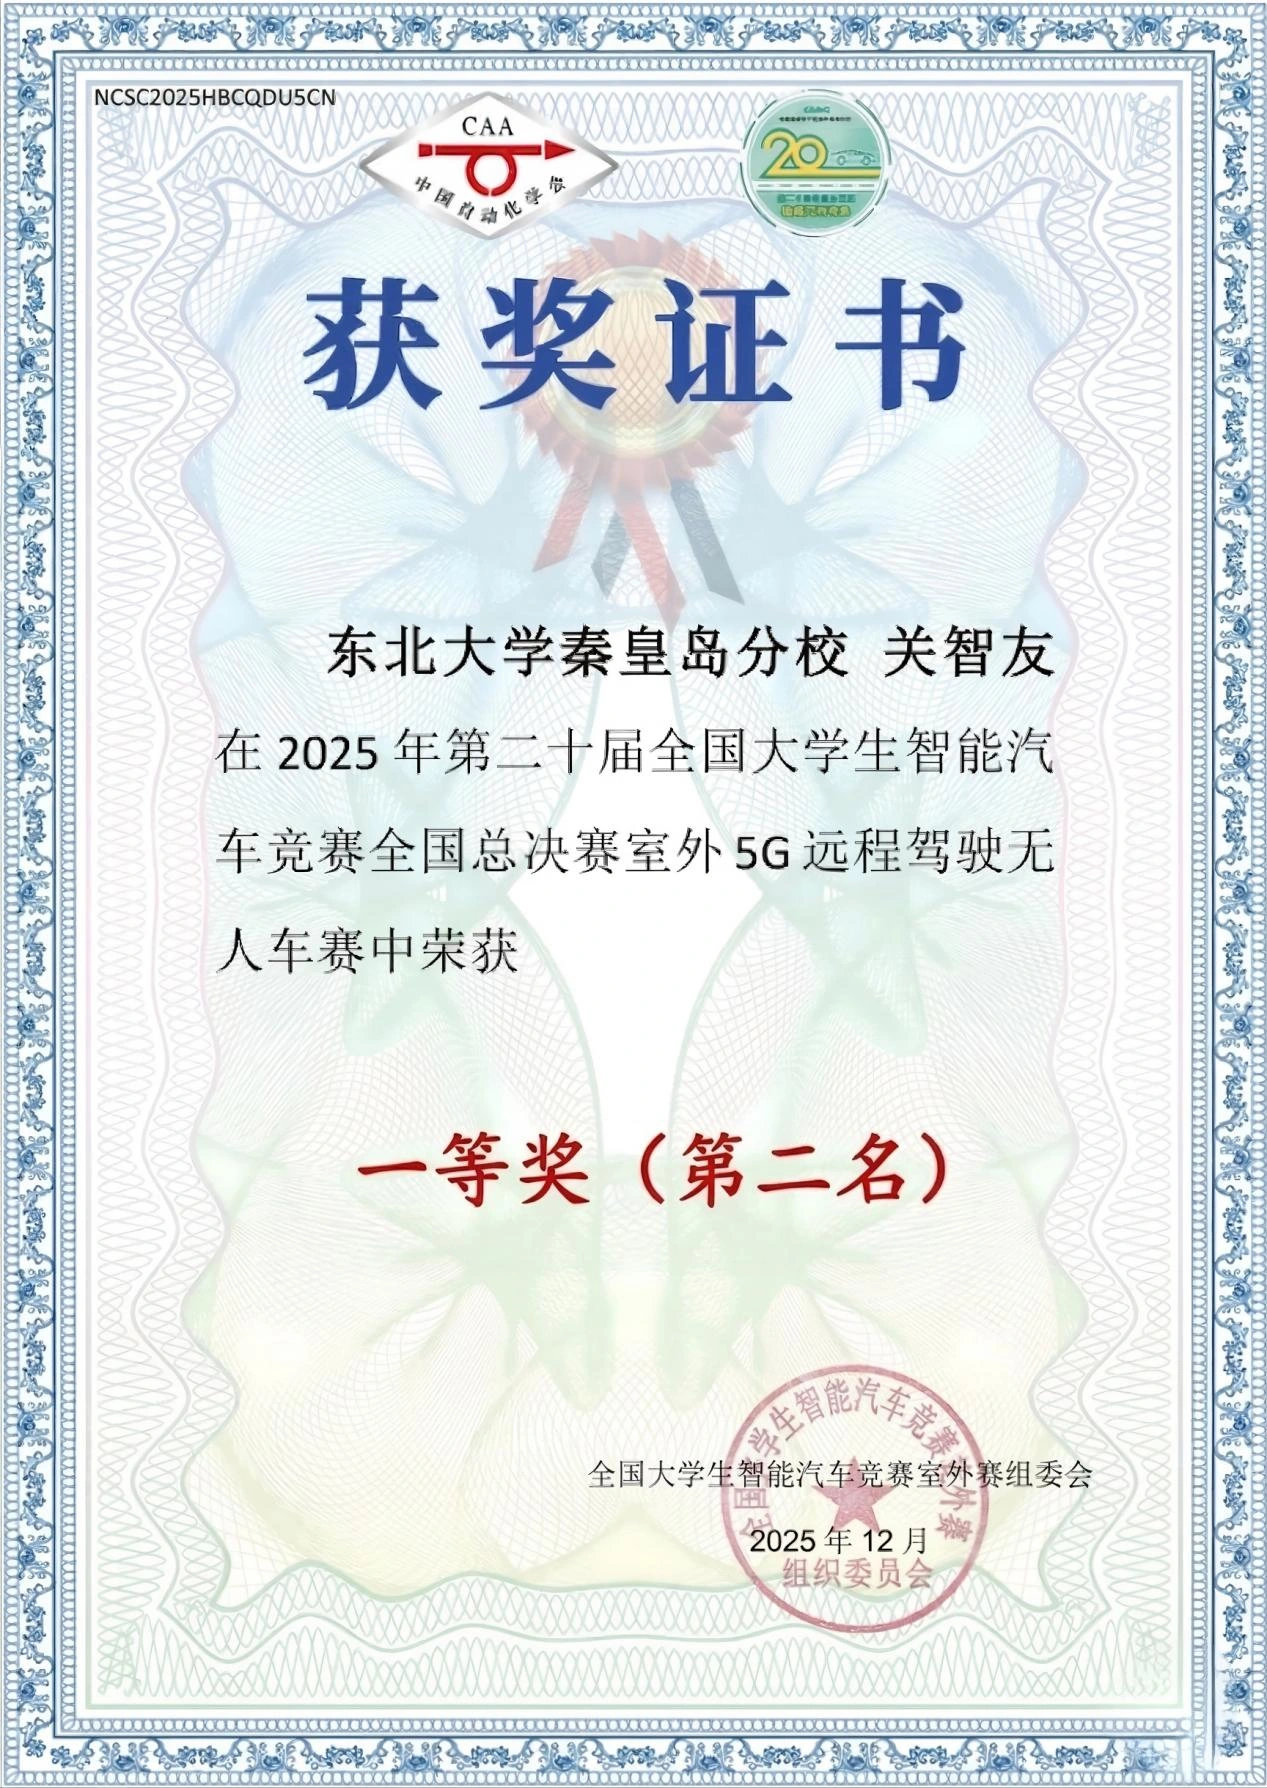
National Runner-up · Smart Car Competition certificate
2025

National Runner-up · Smart Car Competition

Outdoor unmanned vehicle track · Team captain

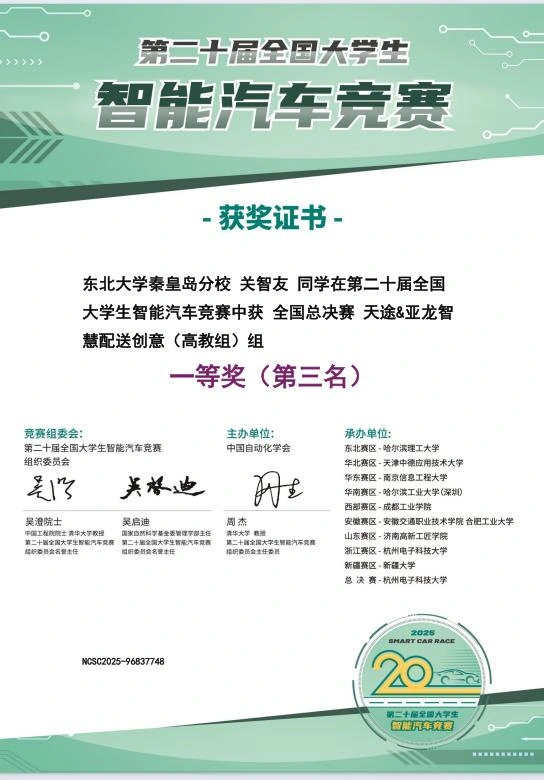
National Third Place · Smart Car Competition certificate
2025

National Third Place · Smart Car Competition

Smart delivery track · Team captain

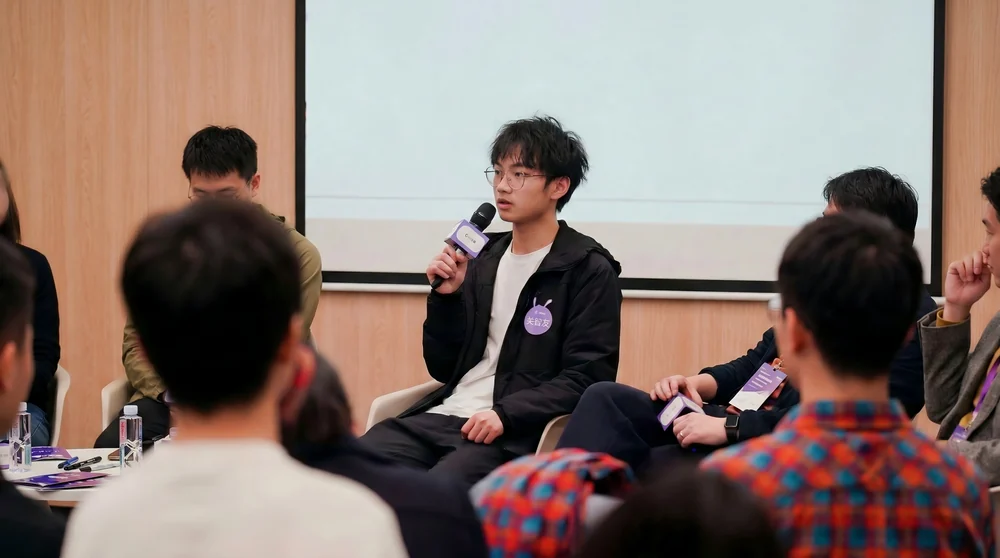
Zhiyou Guan giving a technical talk at DJI

Beyond research

A moment from a technical talk I gave at DJI. I also plan to share paper readings and engineering notes on Bilibili. Videos coming soon.

Find me on Bilibili (new tab)

Contact

If you’re working on robotics, world models, or agents, I’d be happy to hear from you.